| Battery chemistry | Lithium-ion and lithium-polymer packs are common in electric UAVs. The BMS must be configured for the selected cell chemistry and its specified voltage limits. | Voltage thresholds, charging rules, and state-of-charge estimates depend on chemistry and cell specifications. |
| Series cell count | Small UAV packs may use a range of series-connected cells; common configurations include 3S, 4S, 6S, and higher-voltage packs. The BMS must match the pack’s actual series count. | Incorrect cell-count configuration can prevent accurate cell monitoring and safe pack operation. |
| Cell monitoring | Per-cell voltage measurement is used to identify undervoltage, overvoltage, and cell imbalance. Temperature sensing is commonly added at relevant points in the pack. | Pack-level voltage alone can conceal an individual cell that has reached an unsafe limit. |
| Current measurement | Current sensing may use a shunt resistor or a Hall-effect sensor. Sensor range and accuracy should be selected for the UAV’s expected continuous and peak current. | Current data supports overcurrent protection and improves charge, discharge, and remaining-capacity estimates. |
| Protection functions | Typical protection includes cell overvoltage and undervoltage, charge and discharge overcurrent, short-circuit response, and overtemperature limits. | Thresholds and response times should be set to the cell manufacturer’s specifications and the aircraft’s electrical design. |
| Cell balancing | Passive balancing is a common, relatively simple approach; active balancing transfers energy between cells and can be considered where pack size or operating requirements justify added complexity. | Balancing helps keep series-connected cells within a suitable voltage range over repeated charge and discharge cycles. |
| State estimation | State of charge is commonly estimated using current integration, voltage information, and cell-specific calibration. State-of-health estimation may use accumulated operating data. | Estimation quality depends on calibration, sensor accuracy, cell characteristics, and operating conditions. |
| Communications | Common interfaces include UART, CAN, and SMBus/I²C-based connections, depending on the flight controller, battery interface, and system architecture. | Confirm protocol, connector pinout, data format, and fault-reporting behavior before integration. |
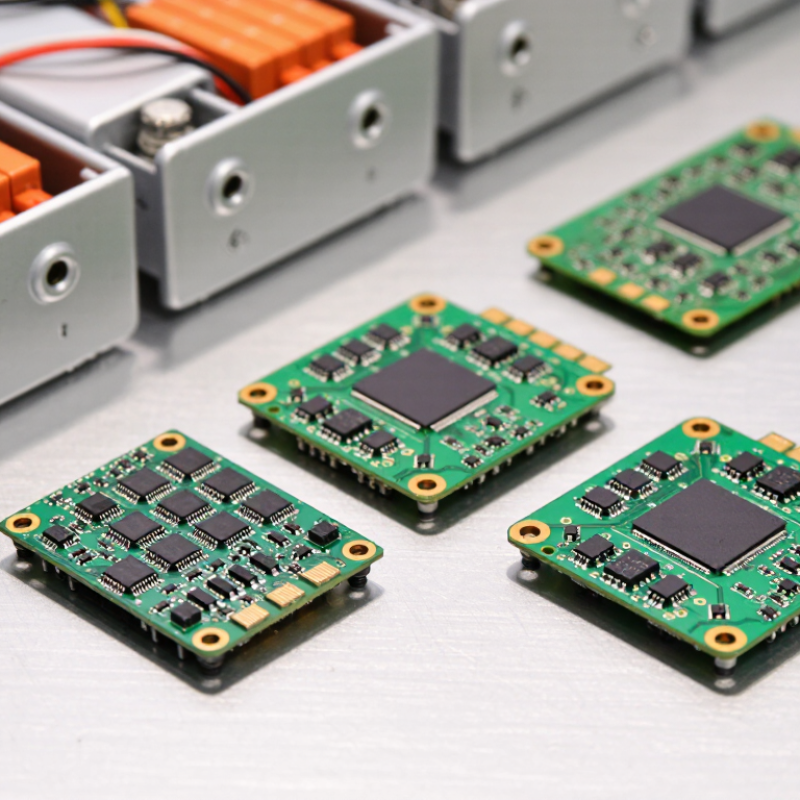
| Size and mass | Board outline, component height, connector placement, and cable routing should be designed around the available battery compartment and vibration environment. | There is no universal “compact” size; acceptable dimensions and mass depend on the airframe and battery-pack design. |
| Operating environment | Specify the required operating-temperature range and consider vibration, moisture exposure, insulation, and electrical-noise conditions in the aircraft. | Environmental requirements affect component selection, enclosure design, sensing accuracy, and reliability. |
| Integration and validation | Review the cell datasheet, wiring diagram, charge profile, firmware settings, and protection thresholds. Verify behavior with controlled tests before flight use. | A BMS should be validated as part of the complete battery and aircraft system, rather than selected by size alone. |
 © Copyright 2020 Tianjin Tanghaidongyang Valve Co., Ltd. All Rights Reserved.